publications

publications by categories in reversed chronological order. generated by jekyll-scholar.

2026

  1. he2026modeling-preview.png
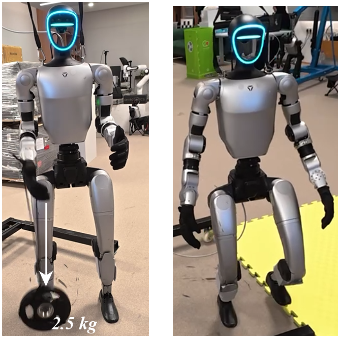
    Modeling and control of a rigid-soft hybrid-link humanoid robot
    Zewen He, Taiki Ishigaki, and Ko Yamamoto
    Robotics and Autonomous Systems, 2026
  2. he2026task-preview.png
    Task-Specified Compliance Bounds for Humanoids via Lipschitz-Constrained Policies
    Zewen He and Yoshihiko Nakamura
    arXiv preprint arXiv:2603.16180, 2026
  3. SMART: Sliding Manifold Action Rectification Technique for Safe Reinforcement Learning
    Jingyu Liu, Yuanda Wang, Zewen He, Anqing Duan, and 2 more authors
    IEEE Transactions on Industrial Informatics, 2026
2025

  1. chen20253d-preview.png
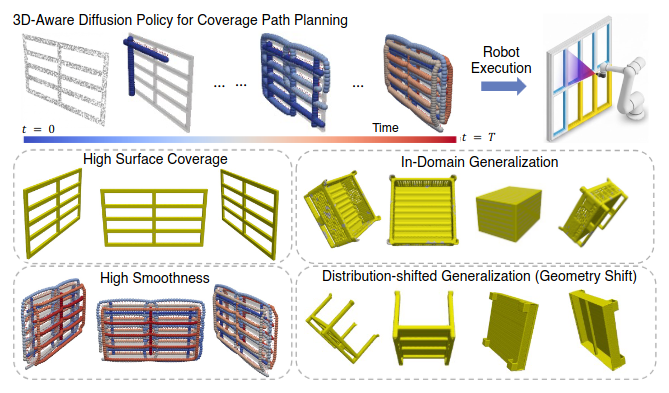
    3D-CovDiffusion: 3D-Aware Diffusion Policy for Coverage Path Planning
    Chenyuan Chen, Haoran Ding, Ran Ding, Tianyu Liu, and 5 more authors
    arXiv preprint arXiv:2510.03011, 2025
  2. he2025cotap-preview.png
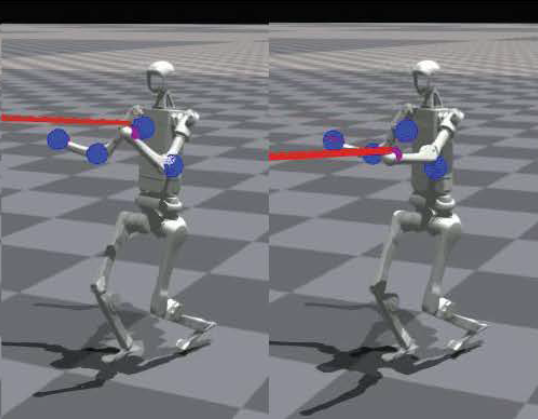
    CoTaP: Compliant Task Pipeline and Reinforcement Learning of Its Controller with Compliance Modulation
    Zewen He, Chenyuan Chen, Dilshod Azizov, and Yoshihiko Nakamura
    arXiv preprint arXiv:2509.25443, 2025

2024

  1. he2024compliance-preview.png
    Compliance optimization control for rigid-soft hybrid system and its application in humanoid robot motion control
    Zewen He, Taiki Ishigaki, and Ko Yamamoto
    In 2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2024
  2. kang2024whole-preview.png
    Whole-body synergy-based balance control for quadruped robots with manipulators on sloped terrains
    Ru Kang, Huifeng Ning, Fei Meng, and Zewen He
    Cyborg and Bionic Systems, 2024

2022

  1. he2022humanoid-preview.png
    Humanoid running based on 3D COG-ZMP model and resolved centroidal viscoelasticity control
    Zewen He and Ko Yamamoto
    In 2022 IEEE-RAS 21st international conference on humanoid robots (humanoids), 2022
  2. he2022decoupling-preview.png
    Decoupling of inertia effect in angular momentum of a humanoid and its application to resolved viscoelasticity control
    Zewen He and Ko Yamamoto
    In 2022 International Conference on Robotics and Automation (ICRA), 2022

2021

  1. he2021controllable-preview.png
    Controllable height hopping of a parallel legged robot
    Zewen He, Fei Meng, Xuechao Chen, Zhangguo Yu, and 4 more authors
    Applied Sciences, 2021

2019

  1. he2019development-preview.png
    Development of a parallel-elastic robot leg for loaded jumping
    Zewen He, Fei Meng, Xuxiao Fan, Ru Kang, and 6 more authors
    In 2019 IEEE 4th international conference on advanced robotics and mechatronics (ICARM), 2019

2018

  1. he2018optimization-preview.png
    Optimization of standing long jump strategy on a small quadruped robot
    Zewen He, Fei Meng, Huaxin Liu, Xuxiao Fan, and 4 more authors
    In 2018 IEEE International Conference on Robotics and Biomimetics (ROBIO), 2018
  2. Method of design optimization and trajectory implementation on a small cat-like robot
    Zewen He, Fei Meng, Huaxin Liu, Lei Wang, and 5 more authors
    In ROMANSY 22–Robot Design, Dynamics and Control: Proceedings of the 22nd CISM IFToMM Symposium, June 25-28, 2018, Rennes, France, 2018