Zewen He | 何 泽文
Robotics Researcher

MBZUAI, Masdar City,
Abu Dhabi, UAE
I am Zewen He (何 泽文), now a Postdoctoral Associate at MBZUAI working with Prof. Yoshihiko Nakamura. I obtained the PhD degree at the University of Tokyo, supervised by Prof. Yamamoto Ko and Prof. Takanori Fukao from 2020 to 2024. Before that, I obtained the master degree at Beijing Institute of Technology, supervised by Prof. Aiguo Ming and Prof. Qiang Huang.
My research interest is AI for robotics, specifically humanoid robots. During my PhD, my research focused on model-based control based on the rigid-soft hybrid model. In my current work, I focus on RL-based locomotion and compliance control for humanoid robots.
news
| Oct 03, 2024 | Starting today, I am joining MBZUAI as a postdoctoral researcher. |
|---|---|
| Sep 20, 2024 | Today, I was awarded a Ph.D. degree by the University of Tokyo!  |
selected publications
-
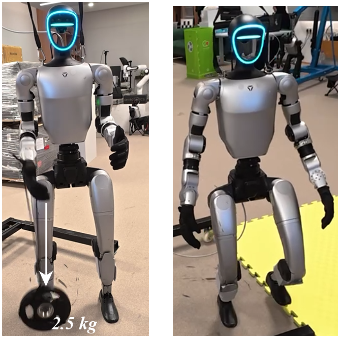 Task-Specified Compliance Bounds for Humanoids via Lipschitz-Constrained PoliciesarXiv preprint arXiv:2603.16180, 2026